4.2.10.1. Cooperation control condition
4.2.10.1. Cooperation control condition
You can monitor the operation preparation, manual cooperation, automatic cooperation, error status etc. of the robot during the cooperation work of the robot using the cooperation control function.
Selection 『[F1]: Service』 → 『1: Monitoring』 → 『10: Cooperation control data』 → 『1: Cooperation control status』
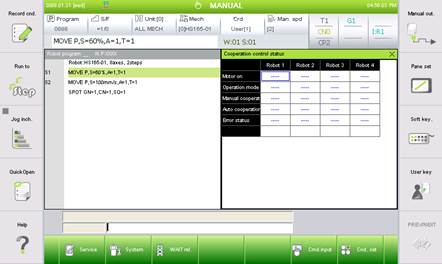
n Motor on : Indicates operation readiness (ON/OFF) of each robot.
n Operation mode : Indicates that each robot is set as manual/auto mode.
n Manual cooperation : Indicates robot’s manual mode cooperative state.
Individual : Individual manipulation state
Master : Set as MASTER in a cooperative manipulation state
Slave : Set as SLAVE in a cooperative manipulation state
n Automatic cooperation : Indicates the cooperative state when a robot performs a task.
Stop : Not performing.
Independent : Independently performing a task
Wait :
Under COWORK command, waiting for a partner robot to be ready for cooperative position.
Cooperation : performing cooperation work.
n Error status
Indicates recent error states of each robot. Error state clears when a robot moves.